ROV · 2026

ROSIE

Remotely Operated Submersible for Innovation and Exploration. Modular, compact, under the 18 kg weight limit, and built around the pressure hull MATE provided.

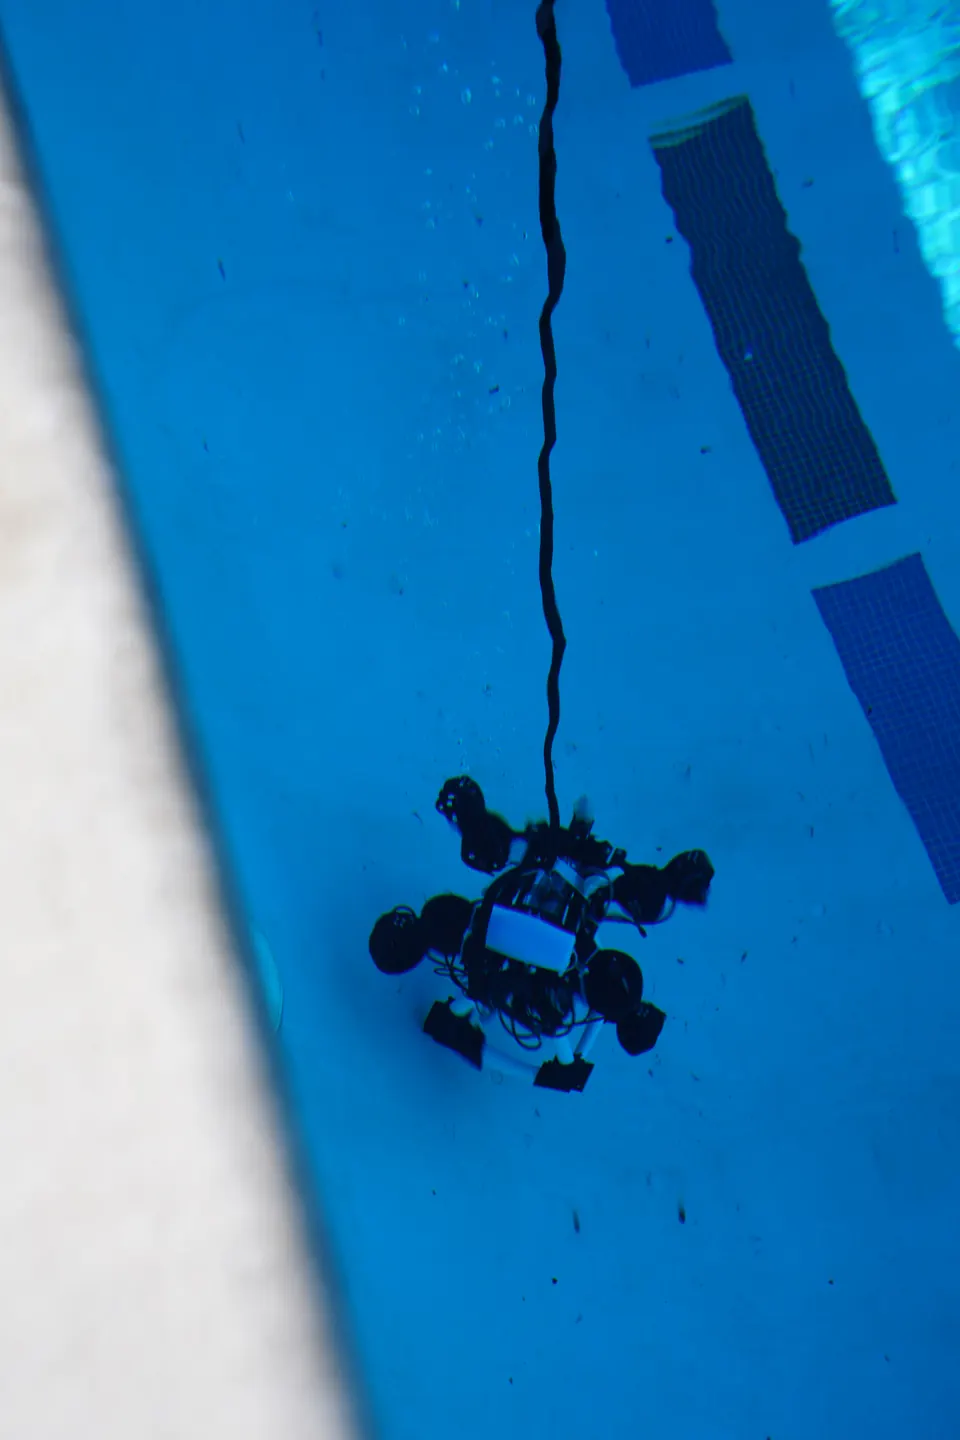
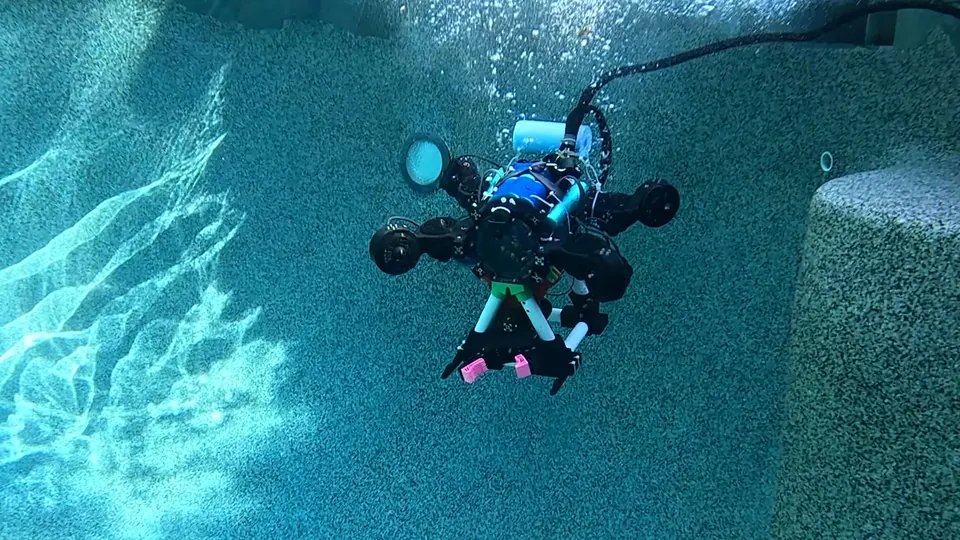
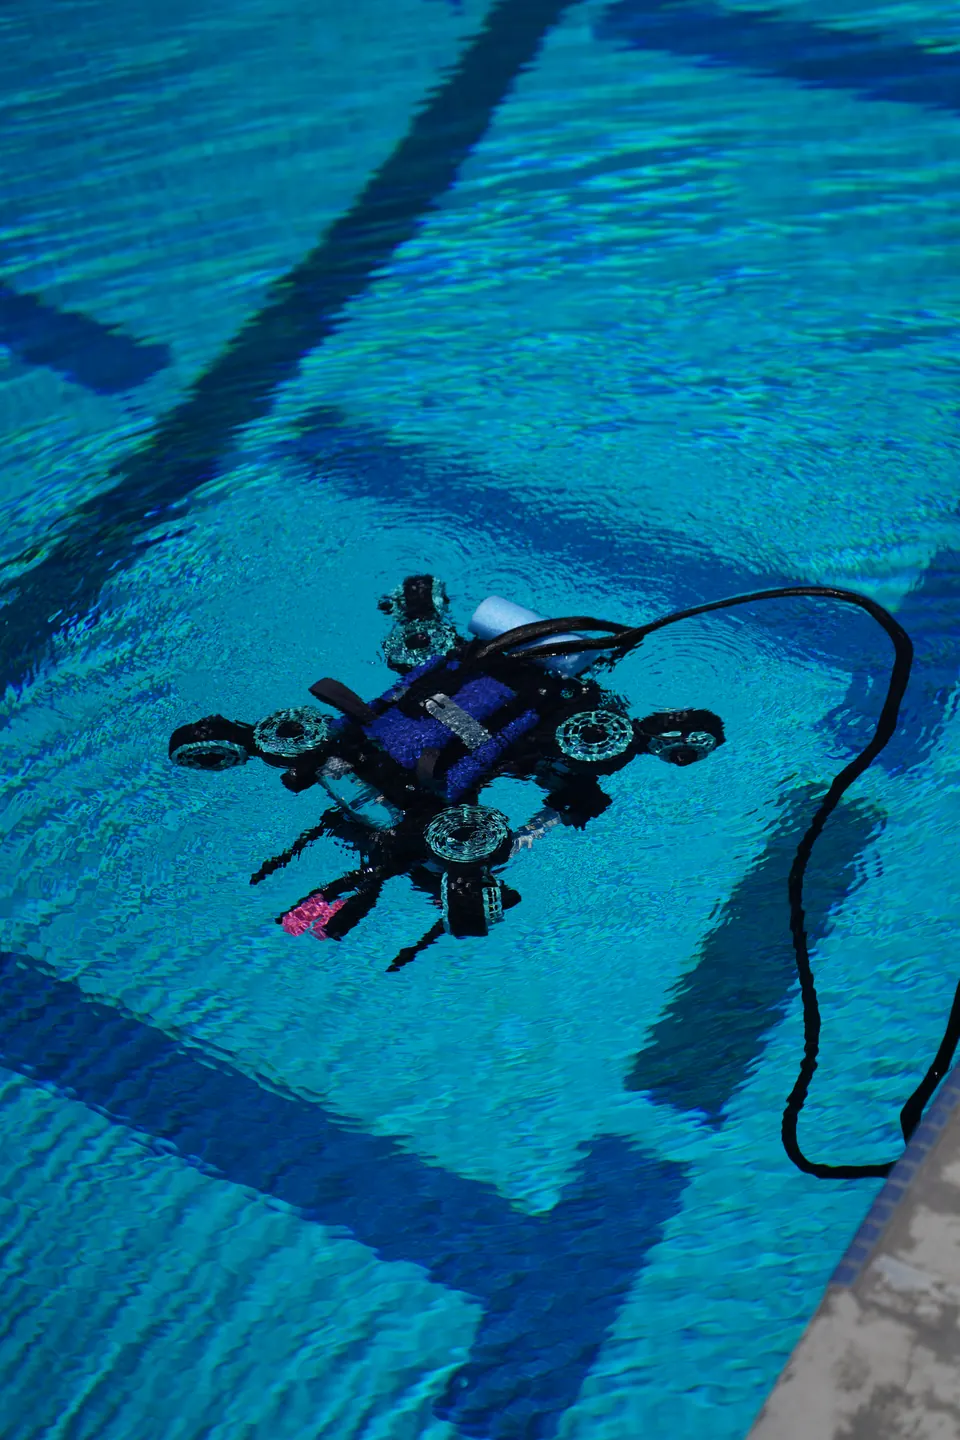
ROSIE underwater in a pool, thrusters and claw visible

Spec sheet

The short version.

Propulsion
8 × Blue Robotics T200, vectored, 6-DOF
Frame
Aluminum T-slot + 3D-printed PETG, TPU feet, PVC legs
Power
48 V / 30 A tether, buck converters to 12 V and 5 V
Compute
Raspberry Pi 4B, Ethernet to a custom surface GUI
Vision
Front, rear and downward cameras; IMU for stability
Tools
Rotating claw (16:1 gearbox), four harpoons, eDNA sampling
Mass
Under 18 kg

In 3D

Turn ROSIE around.

This is our competition CAD, simplified so it loads in a browser. Drag to orbit, pinch or scroll to zoom.

Drag to turn it. Pinch or scroll to zoom.

Exploded view

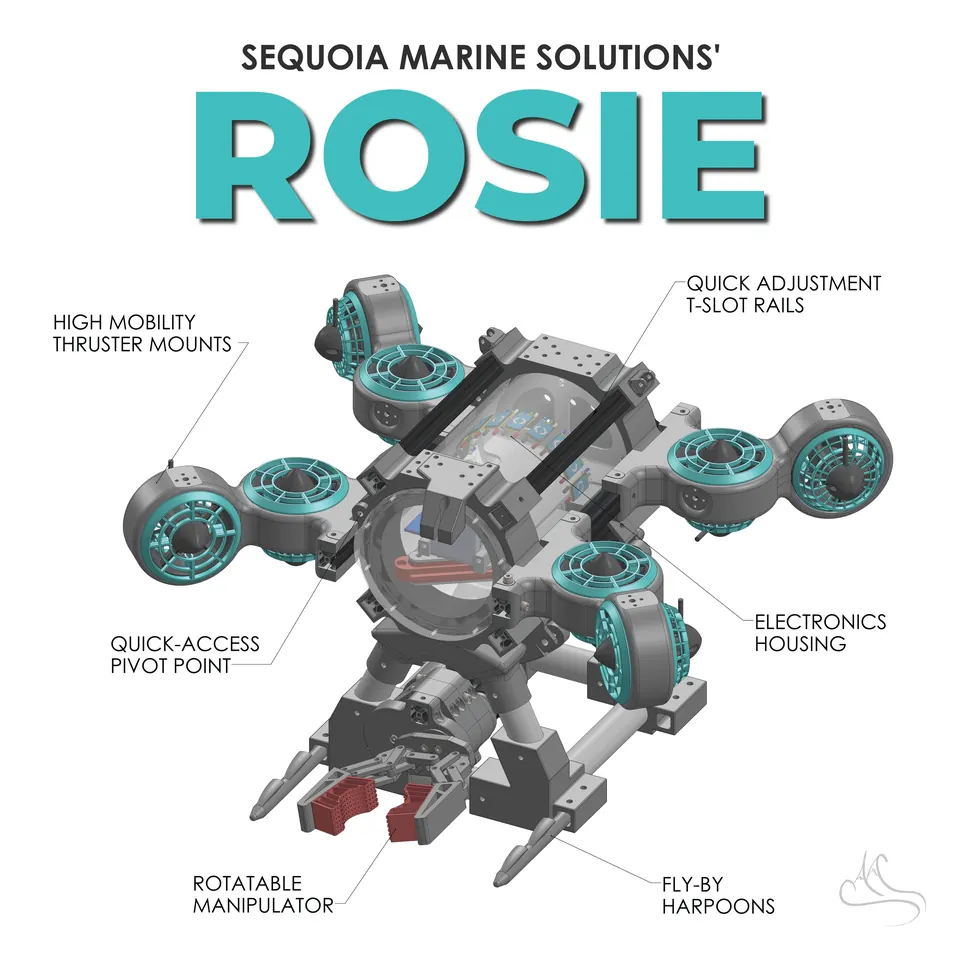
Every part has a job.

ROSIE exploded-view poster with labeled thruster mounts, rails, manipulator and harpoons

Five frames before the final one

Version 0 was a foamboard octagon. Version 1 used PVC pipe so we could test layouts before cutting any aluminum. The final frame uses T-slot rail for modularity, with 3D-printed PETG parts at 35% infill and five walls. PETG won our decision matrix because it doesn't warp in Central Valley heat the way PLA does.
Stacked thrusters, six degrees of freedom

Eight Blue Robotics T200 thrusters in stacked mounts give full 6-DOF control and keep thruster wash off the hull. The layout came from studying MATE's top ten product-demonstration teams.

Harpoons and a rotating claw

Four rigid harpoons grab samples on a drive-by; on the qualification run ROSIE surfaced a basket star, the eDNA sensor, a cap and a coral sample at once. The claw rotates through two 4:1 planetary gearboxes (16:1 total) on plastic bushings that won't rust.

Jigs that saved hours

Loose T-nuts in the rail turned every rebuild into a fight. Thin printed jigs hold them in place, cutting thruster and manipulator setup from about two hours to 30 minutes.

ROSIE in the Fresno State pool, seen from the deck
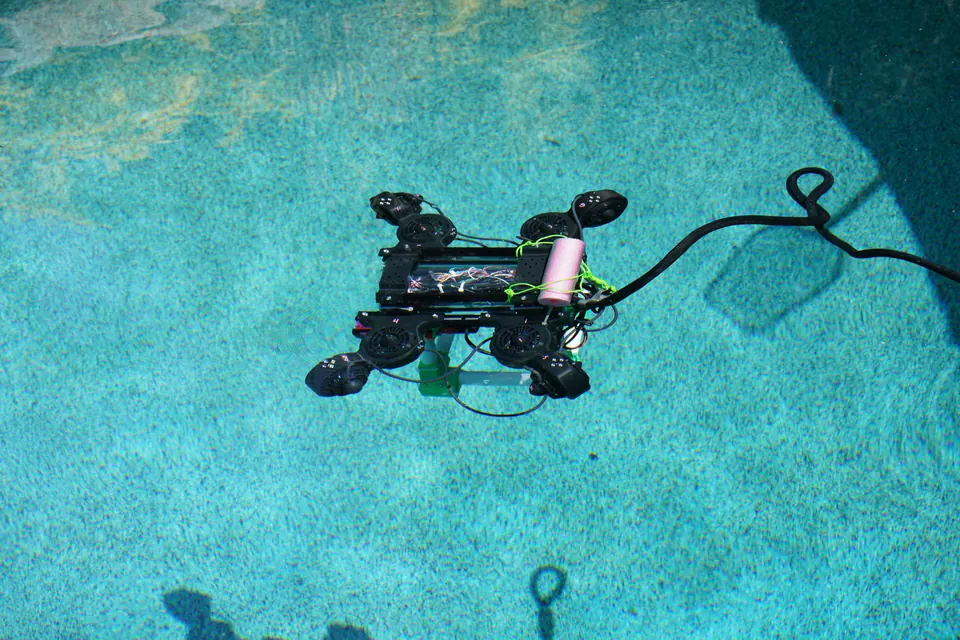
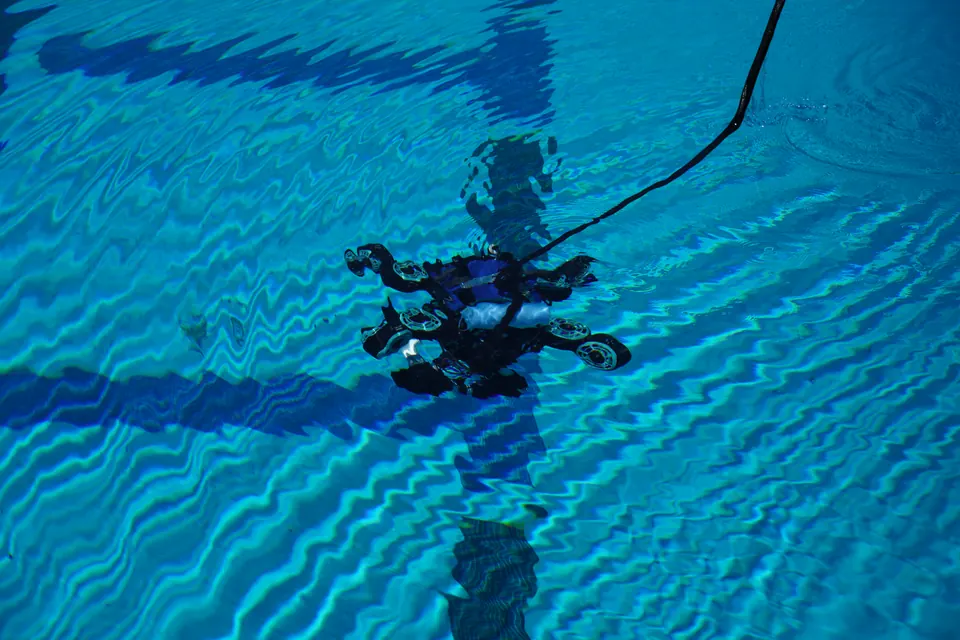
ROSIE underwater, seen from above, trailing its tether
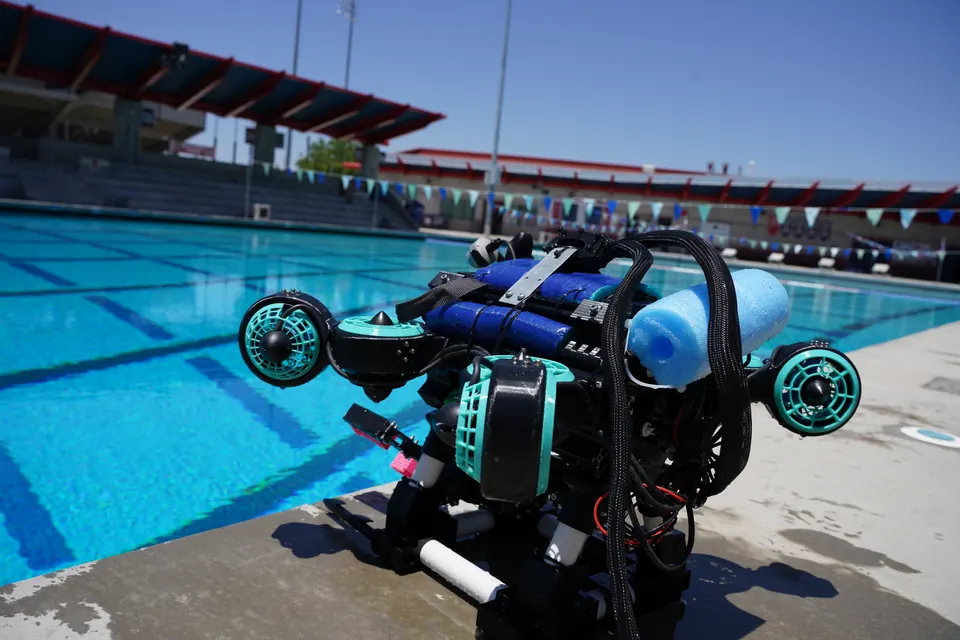
ROSIE on the pool deck at Fresno State, thrusters and claw facing the camera
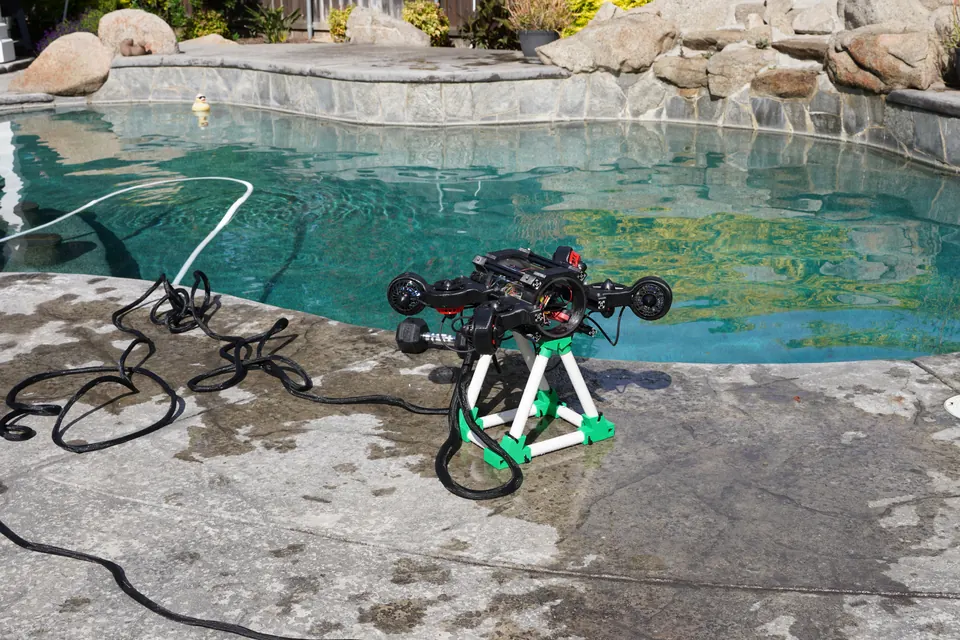
ROSIE flying in a backyard pool during pilot selection, May 2026
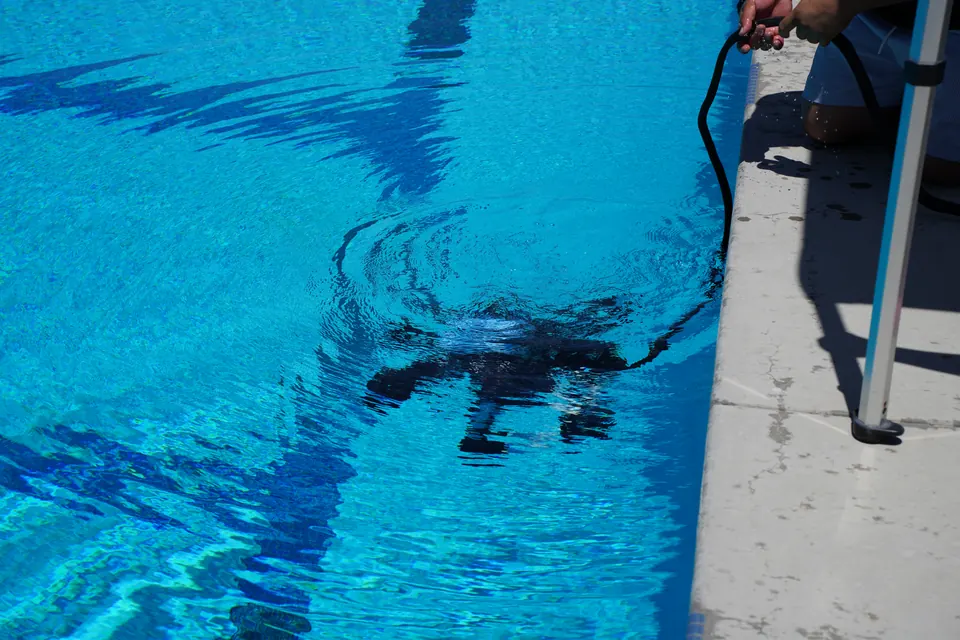
ROSIE under the surface of the Fresno State pool
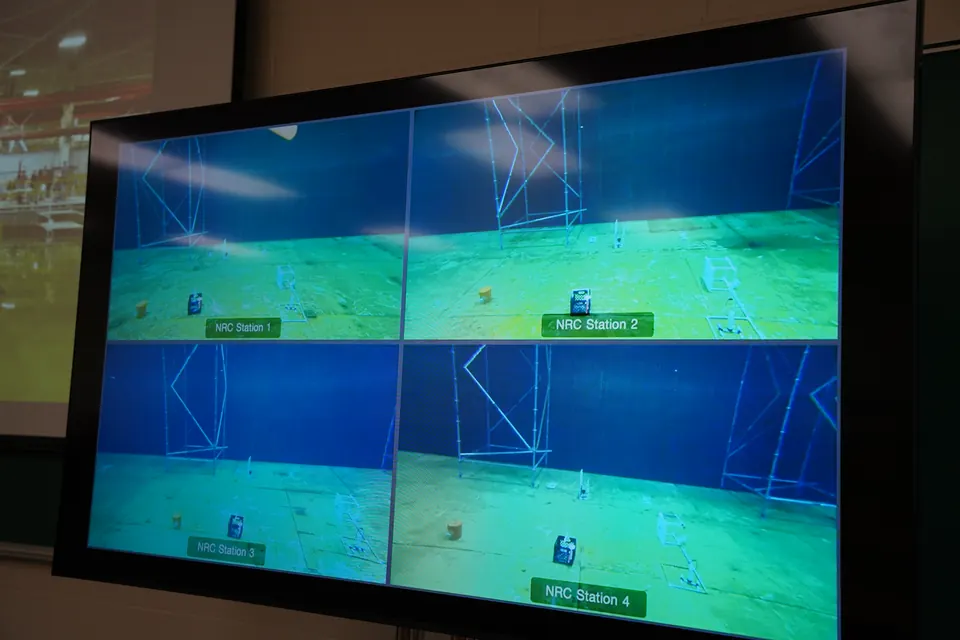
ROSIE's four camera feeds on the pilot screen during a Worlds run
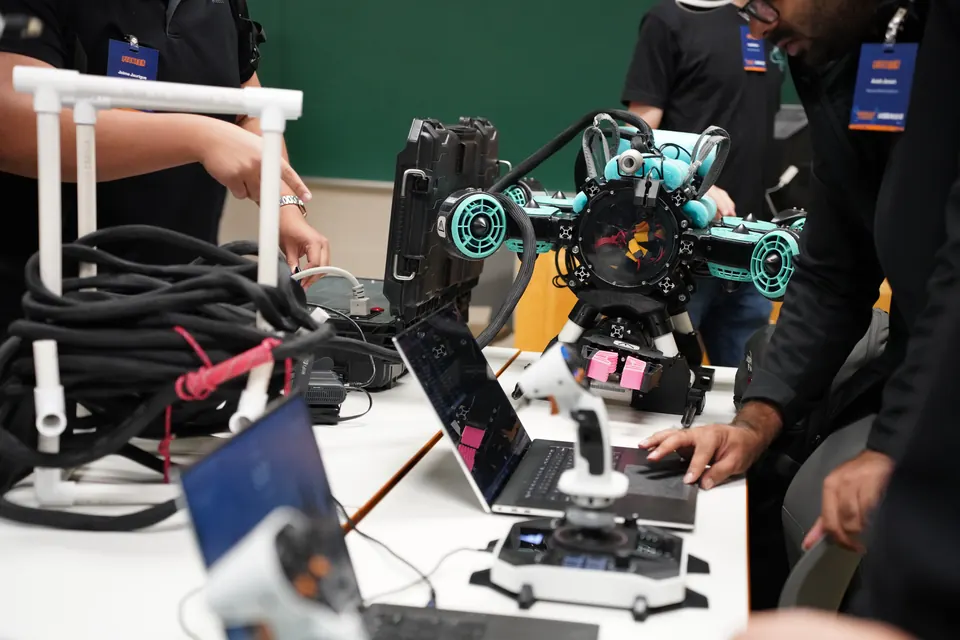
ROSIE beside the pilot station and flight sticks during setup
ROSIE diving in the Fresno State pool, seen from the deck above
An early ROSIE prototype with a PVC frame by a backyard pool
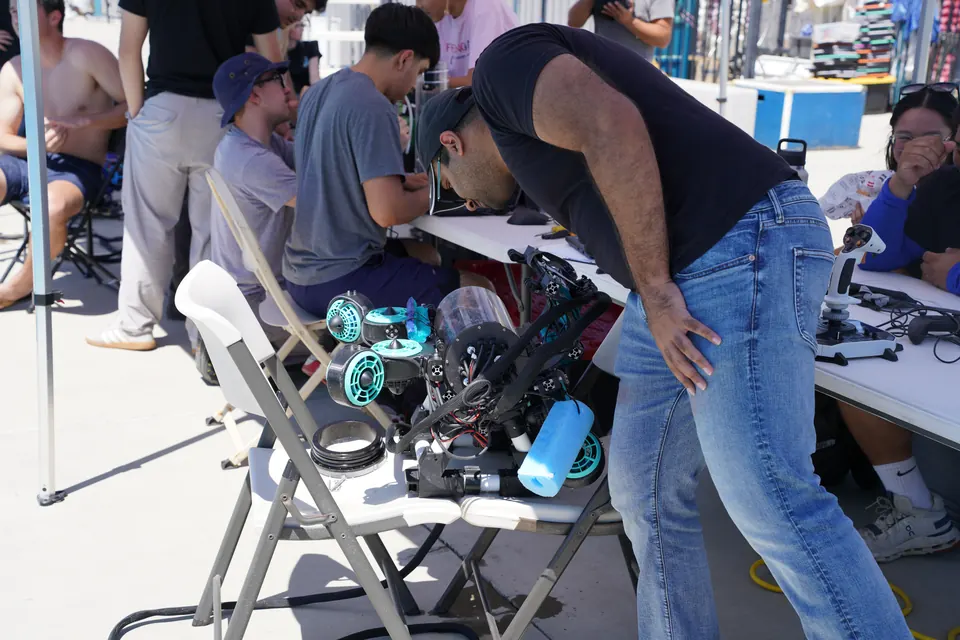
Members working on ROSIE at the SMS and Crush Depth joint showcase