Company

Run like a real firm.

51 students, a C-suite, seven crews with a lead each, and a purchase-request process that goes through design, operations and finance before anything gets ordered.

What we learned

Communication, creativity, autonomy.

From our 2026 company evaluation: with over fifty people involved, structure came first. Then the Chief Design Officer ran idea-generation workshops, which produced the harpoon manipulators. As the year went on, leads handed more ownership to individual members, and the chassis came together from many people's work: thruster shrouds, camera mounts, manipulators.
Join through AVI

Chief Executive Officer

Robert Voss

Computer Science

×
  • Co-founded AVI Robotics and set up SMS as its MATE ROV company.
  • Ran the company and its relationships with sponsors, Fresno State and MATE.
  • Wrote the software libraries the float team built on.

Chief Operating Officer

Timothy Cromwell

Computer Science

×
  • Co-founder of AVI.
  • Ran operations: the master timeline, Friday progress checks and purchase requests.
  • Shot the ROV part photography used across the marketing display.

Chief Technical Officer

Declan Doss

Electrical Engineering

×
  • Co-founder of AVI, and AVI's president for 2026–27.
  • Led the technical side across the ROV and the float subsystems.

Chief Design Officer

Caleb Bahne

Mechanical Engineering

×
  • Ran the idea-generation workshops that produced the harpoon manipulators.
  • Designed the manipulator and float (ADAM) CAD.

Chief Planning Officer

Santiago Flores

Electrical Engineering

×
  • Owned planning, safety and the deck crew that runs the robot from the pool side.

Director of Operations Finance

Jaime Jaurigue

Electrical Engineering

×
  • Ran the money: estimated-expense reports, purchasing and reimbursements, including getting 13 students to Newfoundland.

Director of Marketing

Maria Roceo Sy

Computer Engineering

×
  • Led marketing, including the marketing display.

Crew

ROV Chassis & Propulsion

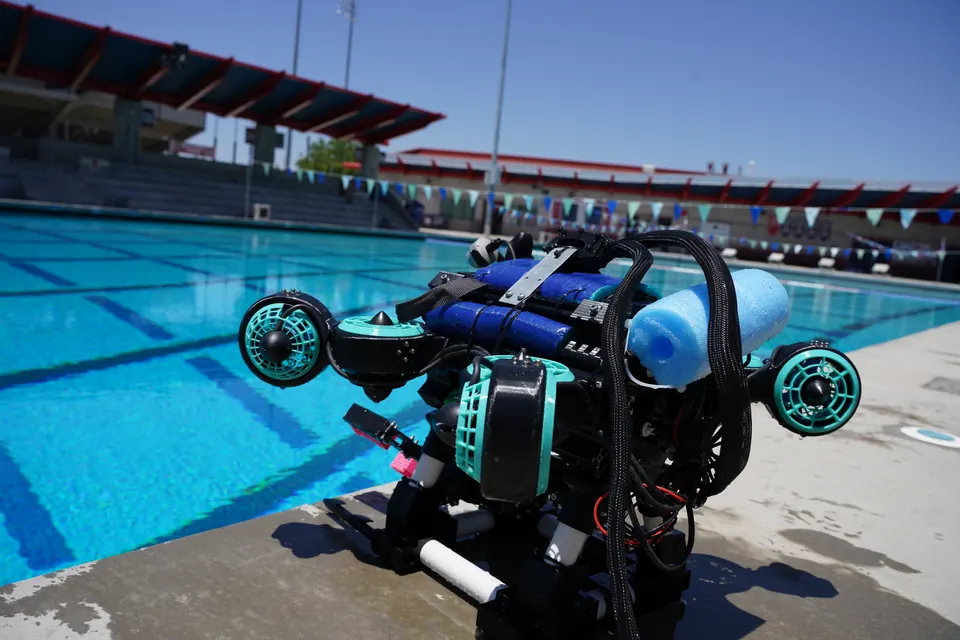
The body of ROSIE: an aluminum T-slot frame around the pressure hull, with eight 3D-printed thruster mounts.

×
ROSIE on the pool deck at Fresno State, thrusters and claw facing the camera

What they built

  • T-slot rail frame that lets anything be mounted and slid into place
  • Eight vectored thrusters in 3D-printed PETG mounts and shrouds
  • A removable hull: the enclosure clamps pivot open for access to the electronics
  • PVC legs for a stable stance on deck

Who

  • Dottie Gunn
    Lead
  • Anapaula Mena
  • Carlos Vidrio Vasquez
  • Dana Martinez
  • Jag Dhillon
  • Jovani Herrera
  • Leilah Hunt
  • Natalie Maciel
  • Robel Gembre
  • Tony Garcia

Crew

ROV Manipulators

Everything ROSIE grabs with: a rotating claw and four harpoons.

×
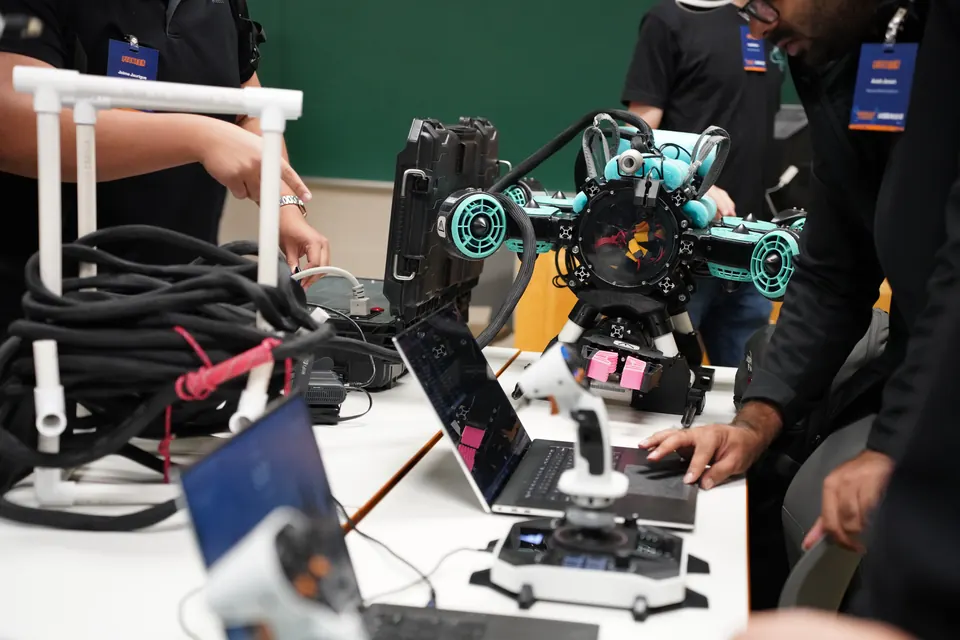
ROSIE beside the pilot station and flight sticks during setup

What they built

  • A claw with a 360-degree rotating wrist, printed in flexible, grippy filament so it doesn't damage specimens
  • Four harpoons that pick up samples and rope on the fly

Who

  • Sam Heinrichs
    Lead
  • Alex Ellis
  • Anthony Nichols
  • Brianna Vidrio
  • Ethan Kelstrom
  • Jovani Mendez
  • Will Junnila

Crew

ROV Controls & Electronics

The ROV's electronics and software: power, motor control and the code the pilots fly.

×
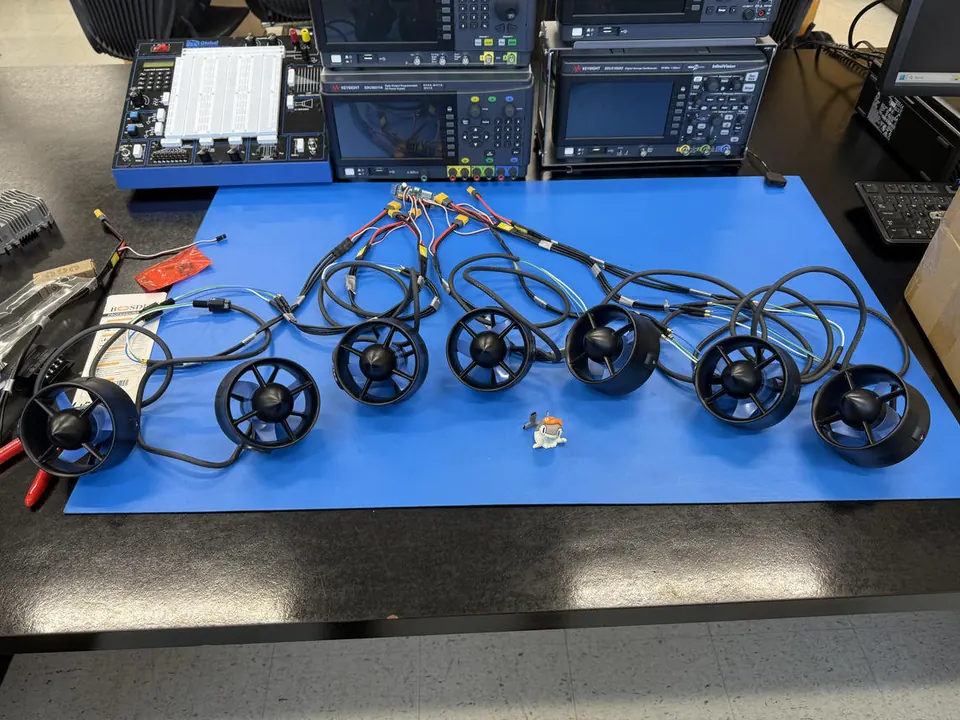
ROSIE's eight thrusters wired up for a bench test

What they built

  • A 48 V / 30 A power system
  • Motor control for eight thrusters
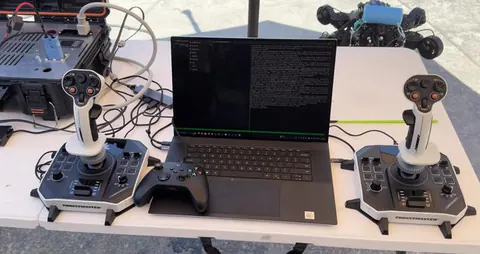
  • Flight-stick piloting with 44 programmable buttons

Who

  • Dalton Cowin
    Lead
  • Clarissa Morgan
  • Earl Orejola
  • Haroon Ahmad

Crew

GUI & Communications

The pilot's screen and the link between the deck and the robot.

×
The SMS pilot station: two flight sticks and the laptop running our pilot GUI

What they built

  • The pilot GUI with camera views
  • Controller mapping for pilot and co-pilot
  • Photogrammetry: building 3D models from the ROV's cameras
  • The tether: power down to the ROV and two-way Ethernet

Who

  • Ansh Josan
    Lead
  • Guillermo Prado (pilot)
  • Kyle Pham
  • Nathaniel Garcia

Crew

Float Chassis & Buoyancy

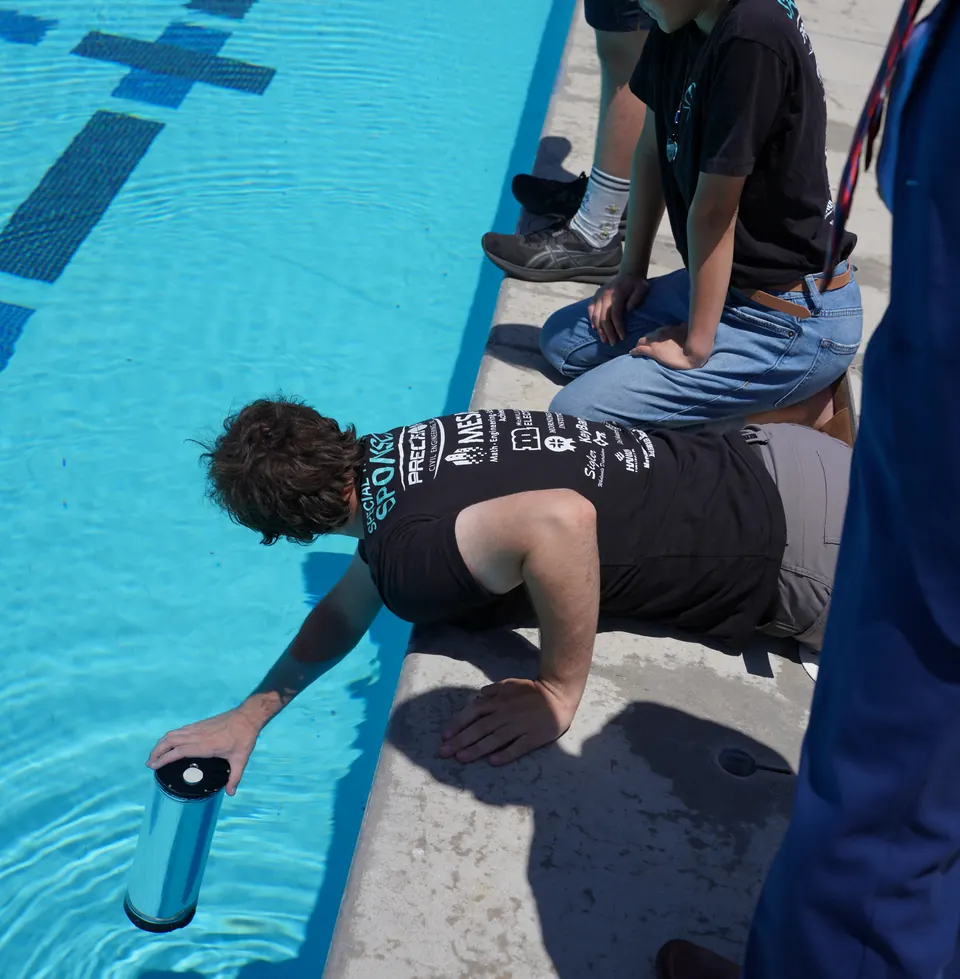
ADAM's body and its buoyancy engine: a pump moves water in and out of a bladder, so the float sinks and rises with no thrusters.

×
A member lowers ADAM, the profiling float, into the Fresno State pool

What they built

  • A peristaltic-pump buoyancy engine
  • Removable internals on rails for easy service
  • Ballast plates to fine-tune mass
  • Cold-tested to 2 °C before competition

Who

  • Cal Limdren
    Lead
  • Christian Thao
  • Ethan Fernandez
  • Jonathan Camarena
  • Kellen Davis
  • Lizbet Robledo
  • Mario Ortiz

Crew

Float Controls & Electronics

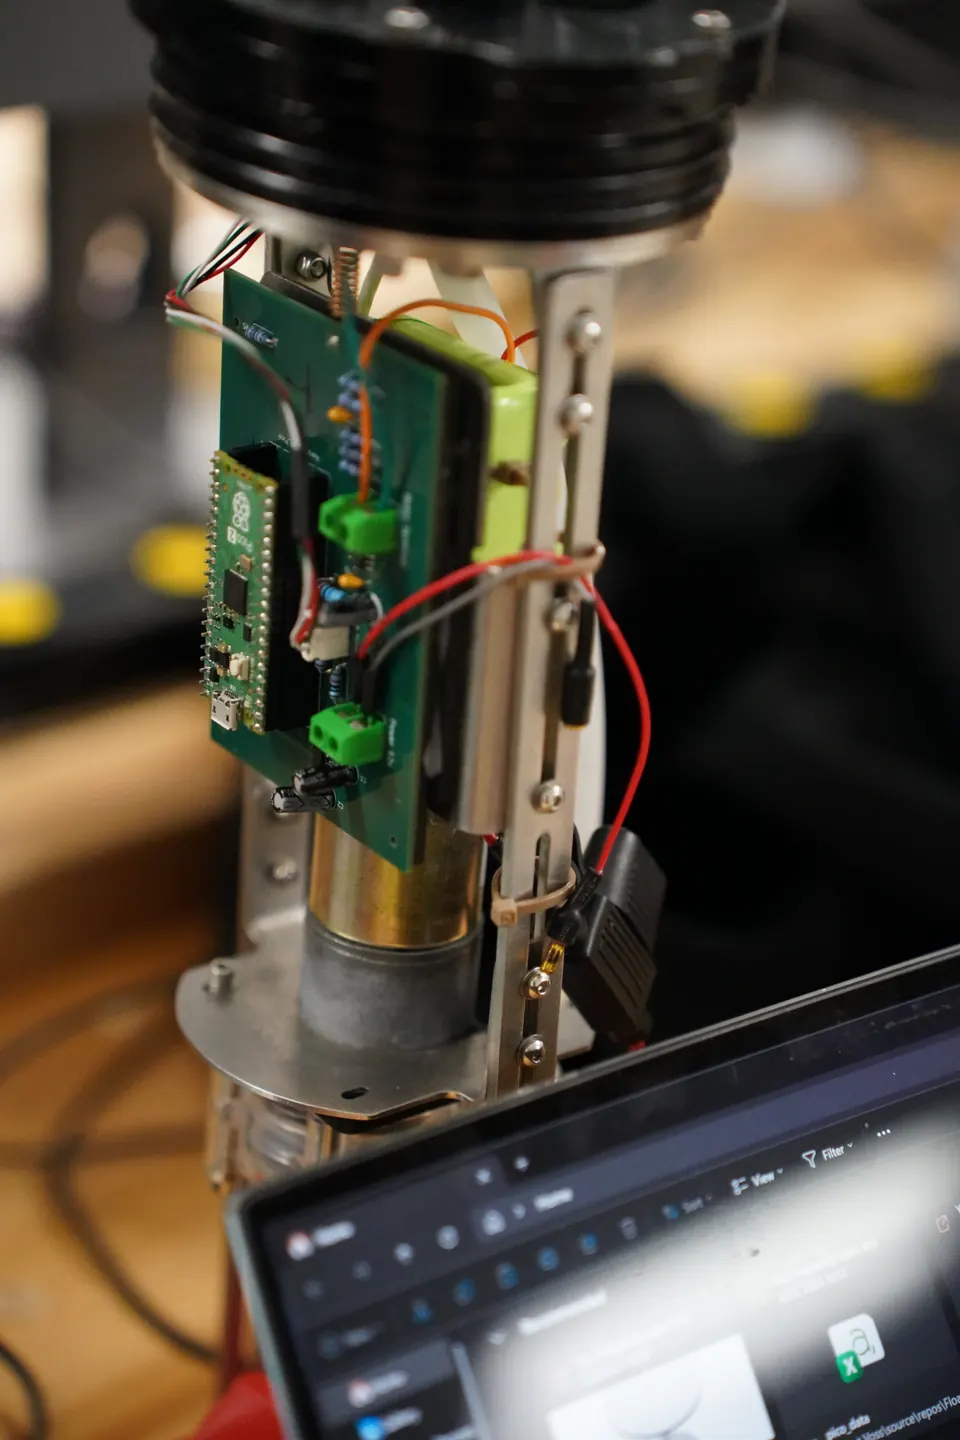
ADAM's brain: custom PCBs, sensors and the code for vertical profiles.

×
ADAM's custom electronics inside the clear float tube

What they built

  • Three generations of custom PCBs designed in KiCad
  • Vertical-profiling and collision-avoidance software
  • The surface receiver and float GUI

Who

  • Matthias Cockrum
    Lead
  • Andres Jimenez
  • Ekin Thao
  • Jonathan Anguiano
  • Luis Delgado
  • Wyatt Grogan

Crew

Deck Management

The crew on the pool deck: tether handling, safety and running the mission clock.

×
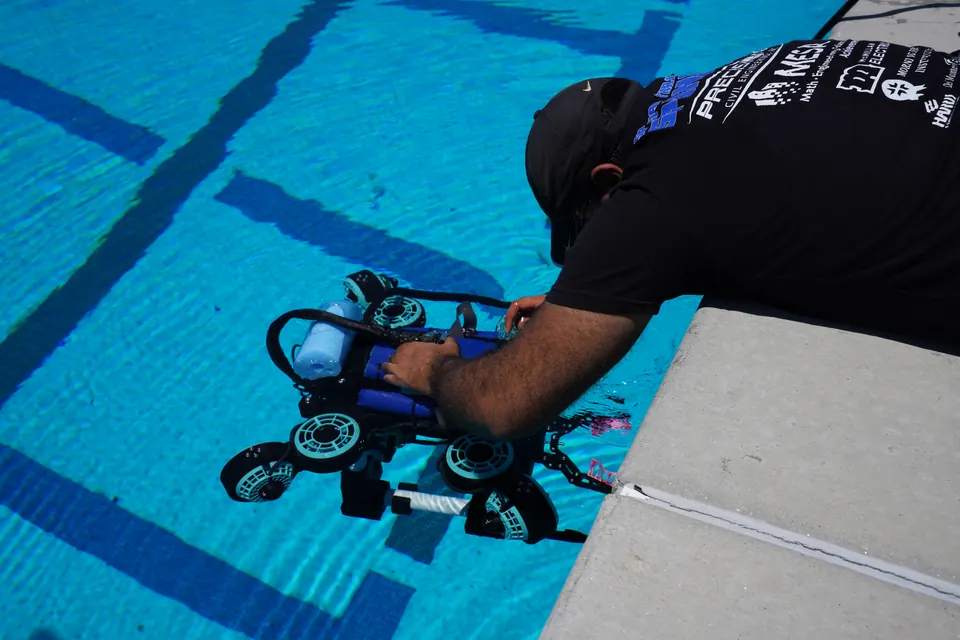
A team member lowers ROSIE into a pool during testing

What they built

  • Tether management on deck
  • Safety procedures and the job safety analysis

Who

  • Santiago Flores
    Lead
  • Abraham Cortes
  • Christopher Torres
  • Evencio Cortes
  • Robert Jason Capps